Firmware · Controls · STM32
Embedded
Writes the firmware that makes the robot move, aim, and respond in real time.
What we do
- Write bare-metal embedded C++ on STM32 microcontrollers
- Build hardware drivers for UART, I2C, and CAN
- Control wheels, aiming, and projectile velocity
- Tune driver input and power use for smooth operation
- Test and iterate on the robot with the Electrical team
Skills you’ll build
- Embedded C++ on STM32
- Hardware drivers: UART, I2C, CAN
- Control algorithms
- Hands-on debugging
Example work
- Motor control
- Gimbal control loop
- Board-to-board communication
Gallery
Embedded at work
In person
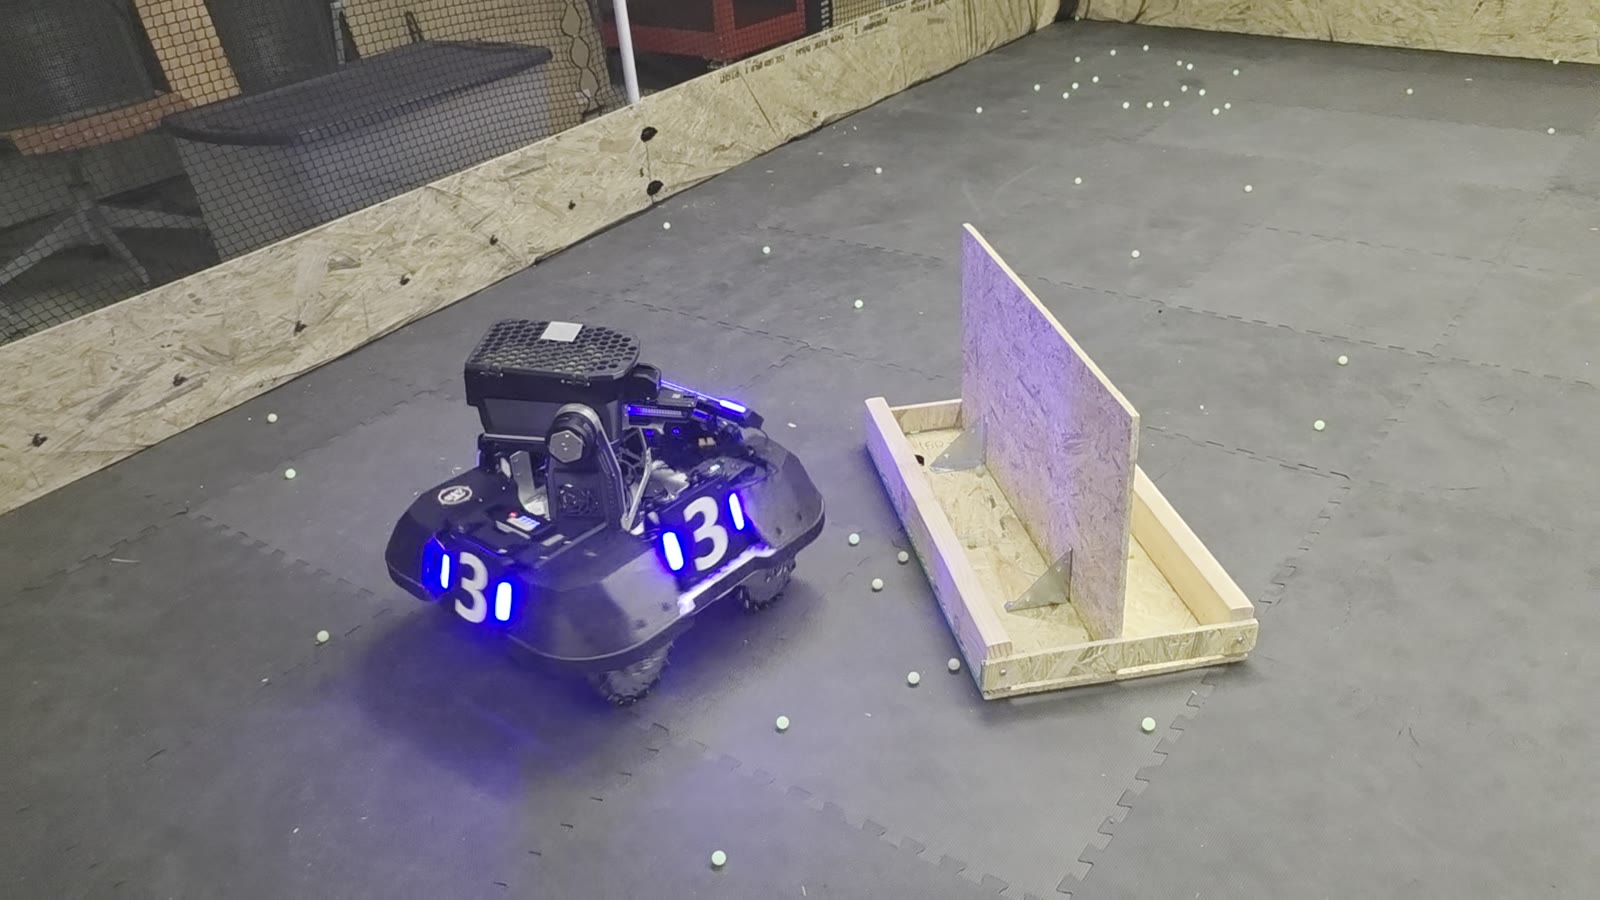
Image 1 of 3: The Infantry robot on a driving test in the practice arena
CAD & presentations
Control loop diagram
Image 1 of 3: Control loop diagram